
Freshly Printed - allow 7 days lead
Couldn't load pickup availability
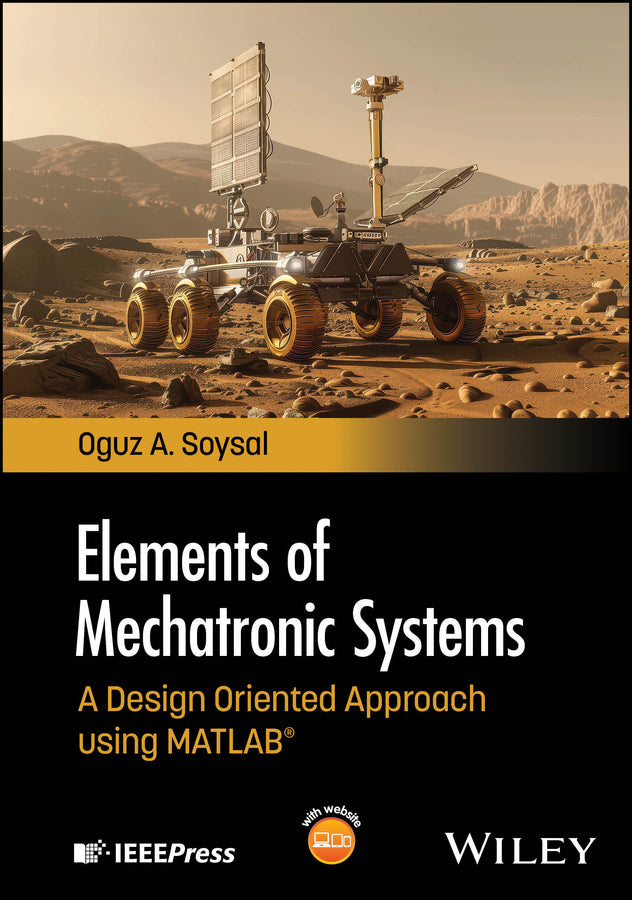
Elements of Mechatronic Systems
A Design Oriented Approach using MATLAB
Oguz A. Soysal (Author)
9781394339716, Wiley
Hardback, published 29 June 2026
512 pages
25.4 x 17.8 x 3.1 cm, 1.074 kg
A unified design approach to mechatronic system fundamentals using MATLAB® Mechatronic system design demands integrated knowledge spanning classical mechanics, electronics, and control theory, yet most references treat these domains in isolation. Elements of Mechatronic Systems: A Design Oriented Approach using MATLAB® presents these disciplines as a single coherent framework, progressing from foundational components such as filters, power converters, and logic circuits through electromechanical energy conversion and electric machines. The text covers resistive, electromagnetic, and optoelectronic sensor types in detail and dedicates a full chapter to digital control using microprocessors and microcomputers. Design examples and simulations use MATLAB® Live Script, enabling readers to automate routine calculations. Each chapter includes solved examples, case studies, and self-assessment quizzes that reinforce core mechatronic control strategies and system design processes. The book also provides: Designed for upper division undergraduate and graduate students in mechatronic design, electronics, and robotics courses, this text also serves as a reference for professors, lecturers, and researchers. Its unified treatment and structured pedagogy support both classroom instruction and independent professional study of mechatronic systems.
About the Author xix 1 Overview 1 2 Basic Concepts 19 3 Dynamic System Modeling 46 4 Sensors 91 5 Signal Conditioning 125 6 Magnetic Circuits and Static Devices 170 7 Electromechanical Energy Conversion 196 8 Rotating Electric Machines 236 9 Electronic Converters 292 10 Motion Transmission and Conversion 340 11 Analog Control 356 12 Digital Control 393 13 Design Considerations 425 Appendix A Integral Transforms 451 Index 471
Preface xxi
Acknowledgments xxv
About the Companion Website xxvii
1.1 Evolution of Mechatronics 2
1.2 Anatomy of Mechatronic Systems 3
1.3 Building Blocks of Mechatronic Systems 5
1.4 Mechatronic Control Strategies 7
1.5 Applications of Mechatronics Technology 9
1.6 Mechatronic System Design Process 10
1.7 Summary 11
1.8 Check Your Understanding 13
References 18
2.1 Newton’s Laws 19
2.2 Work, Energy, and Power 22
2.3 Conservation Principles 26
2.4 Electric Circuits 30
2.5 Summary 39
2.6 Check Your Understanding 40
References 44
3.1 System Identification 47
3.2 Limitations, Constraints, and Assumptions 49
3.3 Linearization Techniques 50
3.4 Through Variables and Across Variables 53
3.5 Electrical Elements 53
3.6 Mechanical Elements 54
3.7 Hydraulic and Pneumatic Elements 61
3.8 Thermal Elements 66
3.9 Dynamic System Response 70
3.10 First-Order System 77
3.11 Second-Order Systems 82
3.12 Summary 84
3.13 Check Your Understanding 85
References 90
4.1 Sensor Types 92
4.2 Signal Generation and Interfacing 96
4.3 Practical Sensors 104
4.4 Encoders 113
4.5 Temperature Sensors 114
4.6 Light Sensors 114
4.7 Integration of Sensors with Electric Circuits 115
4.8 Key Features of Sensor Characteristics 116
4.9 Calibration and Compensation 117
4.10 Design Examples 118
4.11 Summary 120
4.12 Check Your Understanding 121
References 124
5.1 Signals 125
5.2 Signal Sources 134
5.3 Signal Amplification 136
5.4 Operational Amplifiers 138
5.5 Filters 148
5.6 High-Order Filters 161
5.7 Modulation 162
5.8 Summary 162
5.9 Check Your Understanding 165
References 169
6.1 Fundamental Concepts 170
6.2 Magnetic Circuits 173
6.3 Properties of Ferromagnetic Materials 181
6.4 Inductor 185
6.5 Transformer 185
6.6 Summary 189
6.7 Check Your Understanding 191
References 195
7.1 Energy Flow in Electromechanical Devices 196
7.2 Energy Balance 199
7.3 Energy Stored in Magnetic Field 201
7.4 Lorentz Force 203
7.5 Linear Transducers 206
7.6 Rotary Transducers 217
7.7 Multiple Input Multiple Output (MIMO) Electromechanical Systems 221
7.8 Electrostatic Energy Conversion 224
7.9 Design Examples 227
7.10 Summary 229
7.11 Check Your Understanding 230
References 235
8.1 Variable Reluctance Motors 237
8.2 Stepper Motors 242
8.3 Synchronous Machines 247
8.4 Asynchronous (Induction) Motors 255
8.5 DC Machines 270
8.6 Brushless DC Motors 285
8.7 Summary 285
8.8 Check Your Understanding 287
References 291
9.1 Power Semiconductors 294
9.2 AC-to-DC Converters (Rectifiers) 299
9.3 DC-to-DC Converters 307
9.4 DC-to-AC Converters 319
9.5 Variable Frequency Drives 328
9.6 Summary 330
9.7 Check Your Understanding 333
References 339
10.1 Rotary Transmission 341
10.2 Linear (Translational) Transmission 346
10.3 Conversion of Rotary Motion to Translational 347
10.4 Characteristic Parameters of Motion Transmission and Conversion 350
10.5 Application Examples 350
10.6 Selection Criteria for Motion Transmission Mechanisms 351
10.7 Summary 351
10.8 Check Your Understanding 352
References 355
11.1 Control Problem 356
11.2 Performance Metrics 360
11.3 Analog Motion Control 362
11.4 Proportional, Integral, and Derivative (PID) Control 382
11.5 Stability 384
11.6 Summary 386
11.7 Check Your Understanding 388
References 392
12.1 Common Digital Architectures 395
12.2 Programmable Logic Controllers (PLC) 403
12.3 Microprocessors and Microcontrollers 404
12.4 Digital-to-Analog Conversion 407
12.5 Analog-to-Digital Conversion 409
12.6 Digital Signal Conditioning 412
12.7 Discrete-Time Feedback 413
12.8 Performance Criteria 417
12.9 Summary 418
12.10 Check Your Understanding 420
References 423
13.1 Integrated Design Process 425
13.2 Embedded System Control Strategies 428
13.3 Communication Networks and Middleware in Mechatronic Systems 433
13.4 Fault Detection and Diagnostics 436
13.5 Standards Commonly Used in Mechatronic Design 440
13.6 Mechatronic Design Workflow and Standards 441
13.7 Example: Design Concept for an Automated Warehouse Conveyor System 441
13.8 Summary 446
13.9 Check Your Understanding 447
References 450
Appendix B Common Fourier Series Expansions 454
Appendix C Symbols, Units, and Conversions 456
Appendix D Analog Circuit Analysis Methods 458
Appendix E Binary Numbers and Logic Functions 462
Appendix F Arduino Programming 467
Subject Areas: Electronics & communications engineering [TJ]